
FCC's ban on Chinese humanoid robots may starve the US firms it aims to help
SOURCE: STARTUPFORTUNE.COM
OCT 04, 2026
Lord Have Mercy as Researchers Create Walking Disembodied Hand Like That Little Guy From “The Addams Family”
SOURCE: FUTURISM.COM
SEP 27, 2026

Published Sep 27, 2026
Add Futurism(opens in a new tab)
More information
ETH Zurich
Can’t-miss innovations from the bleeding edge of science and tech
Email addressSign Up
It seems that even Thing from “The Addams Family” isn’t safe from being replaced by machines.
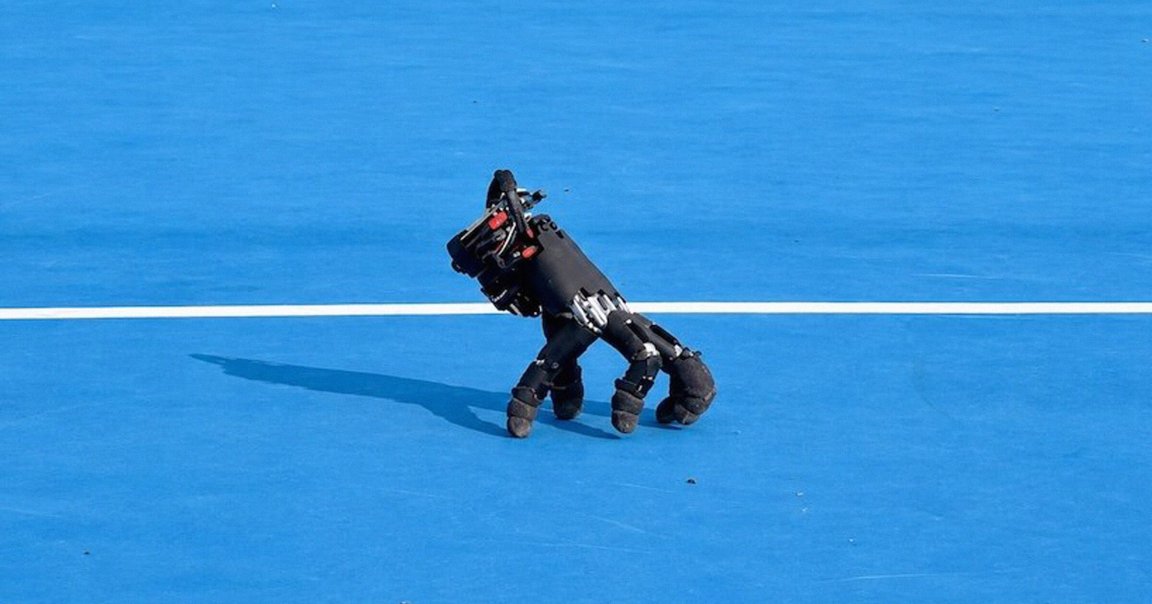
A team of researchers at ETH Zurich’s Soft Robotics Lab have created an anthropomorphic robotic hand that can walk around on its fingertips, all on its own. So dexterous is our disembodied perambulator that it can navigate multiple surfaces and even clack away at a keyboard while supporting its own weight, footage of its exploits shows.
It’s kind of adorable when you watch it in action, like as it plays a game on a computer. But there’s a somewhat creepy, arachnid quality to its twitchy gait — and it’s also, perhaps, reminiscent of a sci-fi horror film’s killer robot that refuses to die even when its body is destroyed. (See also: metamachines.)
Besides haunting a final girl from the grave, an autonomous hand could have some practical applications, the researchers say.
“A robotic hand with its own mobility could operate in confined workspaces without requiring the arm that normally carries it to follow,” the researchers wrote in a new paper about their work. “For example, a larger robot could place the hand on a support surface near a restricted opening. The hand could then move toward a control or object, interact with it, and return for retrieval.”

This Robotic Hand Walks on Its Fingertips
The challenge of creating an autonomous robot hand is that it needs to interact with the environment using the same fingers it uses to walk and keep balance. Adding to the difficulty is that, because the hand is designed to be human-like, the fingers are unequal lengths. In fact, the hand is an off-the-shelf model and the researchers were determined not to modify the fingers or built-in position controller, instead focusing on achieving their goals mainly by teaching the robot.
Some physical modifications were necessary: for it to be self-sufficient, the researchers installed a battery, an onboard computer, and a host of sensors on the hand. Then they trained it in a simulated environment using reinforcement learning, in which the hand’s software is rewarded for correctly completing a task while generally adhering to the fingers’ natural stance.
With enough tries, it eventually worked out how to walk on its own, and soon proved it in the physical world. The disembodied hand was able to walk across over a dozen different indoor and outdoor surfaces, ranging from tiles to grass to stone. These were all flat, but the hand demonstrated it was able to account for the different friction posed by various terrain.
One of the most impressive — and adorable — displays came from when the robot was directed to play a computer game. Keeping its balance the entire time, the hand was able to press individual arrow keys and ace a round of the classic puzzle game Sokoban.
Will we see swarms of disembodied robotic extremities roaming around in the future? Probably not, but they could be used to augment full-sized, humanoid robots.
“Giving robotic hands their own mobility could make future robots more versatile in the spaces and interfaces built for people,” the researchers wrote.

More on robots: Scientists Create New Humanoid Robot That Flinches in Fear When You Come Close
Add Futurism as a preferred source on Google to see more of our reporting.
I’m a tech and science correspondent for Futurism, where I’m particularly interested in astrophysics, the business and ethics of artificial intelligence and automation, and the environment.
LATEST NEWS

Computer Vision
Dual-Stream AI Combines Compression Clues and Deep Vision to Expose Doctored Images
OCT 10, 2026


WHAT'S TRENDING
Data Science
5 Imaginative Data Science Projects That Can Make Your Portfolio Stand Out
OCT 05, 2022


SOURCE: STARTUPFORTUNE.COM
OCT 04, 2026


SOURCE: THEBUSINESSDECK.COM
SEP 27, 2026

SOURCE: RAKSHA-ANIRVEDA.COM
SEP 19, 2026

SOURCE: THEROBOTREPORT.COM
SEP 19, 2026


SOURCE: ROBOTICSTOMORROW.COM
SEP 09, 2026

SOURCE: FINANCE.YAHOO.COM
SEP 02, 2026